NowFlow workflow layer
Connect a request to scoped agents, approved tools, checks and a named human decision. Keep exceptions and recovery steps in the task record.
Inspect NowFlowRobotics and edge AI
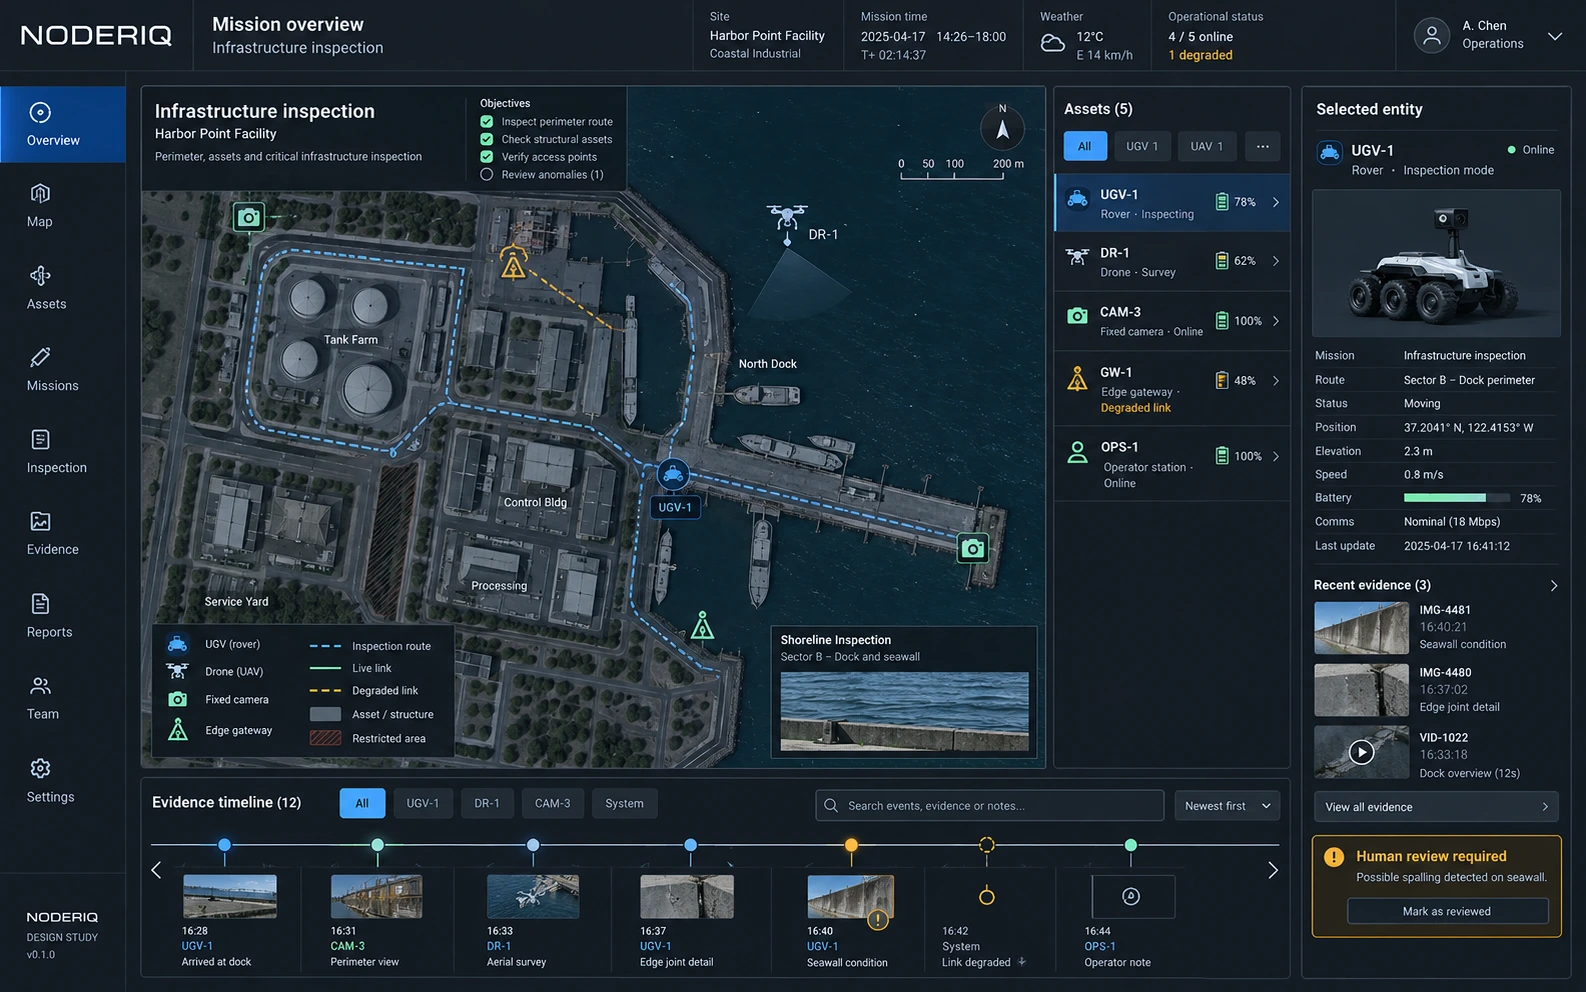
An inspection, transport or field task can cross several devices. A command sent, a command accepted and a physical job completed are different events. NODERIQ keeps that distinction in the mission context.
Explore NODERIQ
Inside NODERIQ
Connect a request to scoped agents, approved tools, checks and a named human decision. Keep exceptions and recovery steps in the task record.
Inspect NowFlowReview device capability, command authority and typed outcomes. Host and QEMU software evidence is distinct from physical-device acceptance. Physical operation remains unapproved.
Inspect NeuraOSDevice controllers retain local motion and safety authority. Consequential workflow release stays human-owned. Compatibility, interfaces and acceptance are defined for each application.
Evaluation
Define a completion test and a stop condition. Replay the same task with a delayed acknowledgement, lost connection or stale observation. Record what is known before approving another action. Moving from software to a physical trial requires a target-specific safety and acceptance plan.
NODERIQ-RCN is the separate collaborative research initiative for shared context and resilient recovery. Consortium development continues. The website console is a controlled browser scenario with no live fleet or physical dispatch.
Technical reading
Task contracts, capability matching, human release and completion evidence.
Shared resources, device roles and interfaces between different systems.
Recommendations, uncertainty, escalation and who can approve an action.
A research scenario for delayed acknowledgements and uncertain outcomes.