When the network becomes unreliable, what does the mission know?
Neura Parse founder and technical lead Bayram Yüksel Eker will speak at the CRANE Safe and Secure Robotics Special Interest Group seminar series on Friday, 13 November 2026.
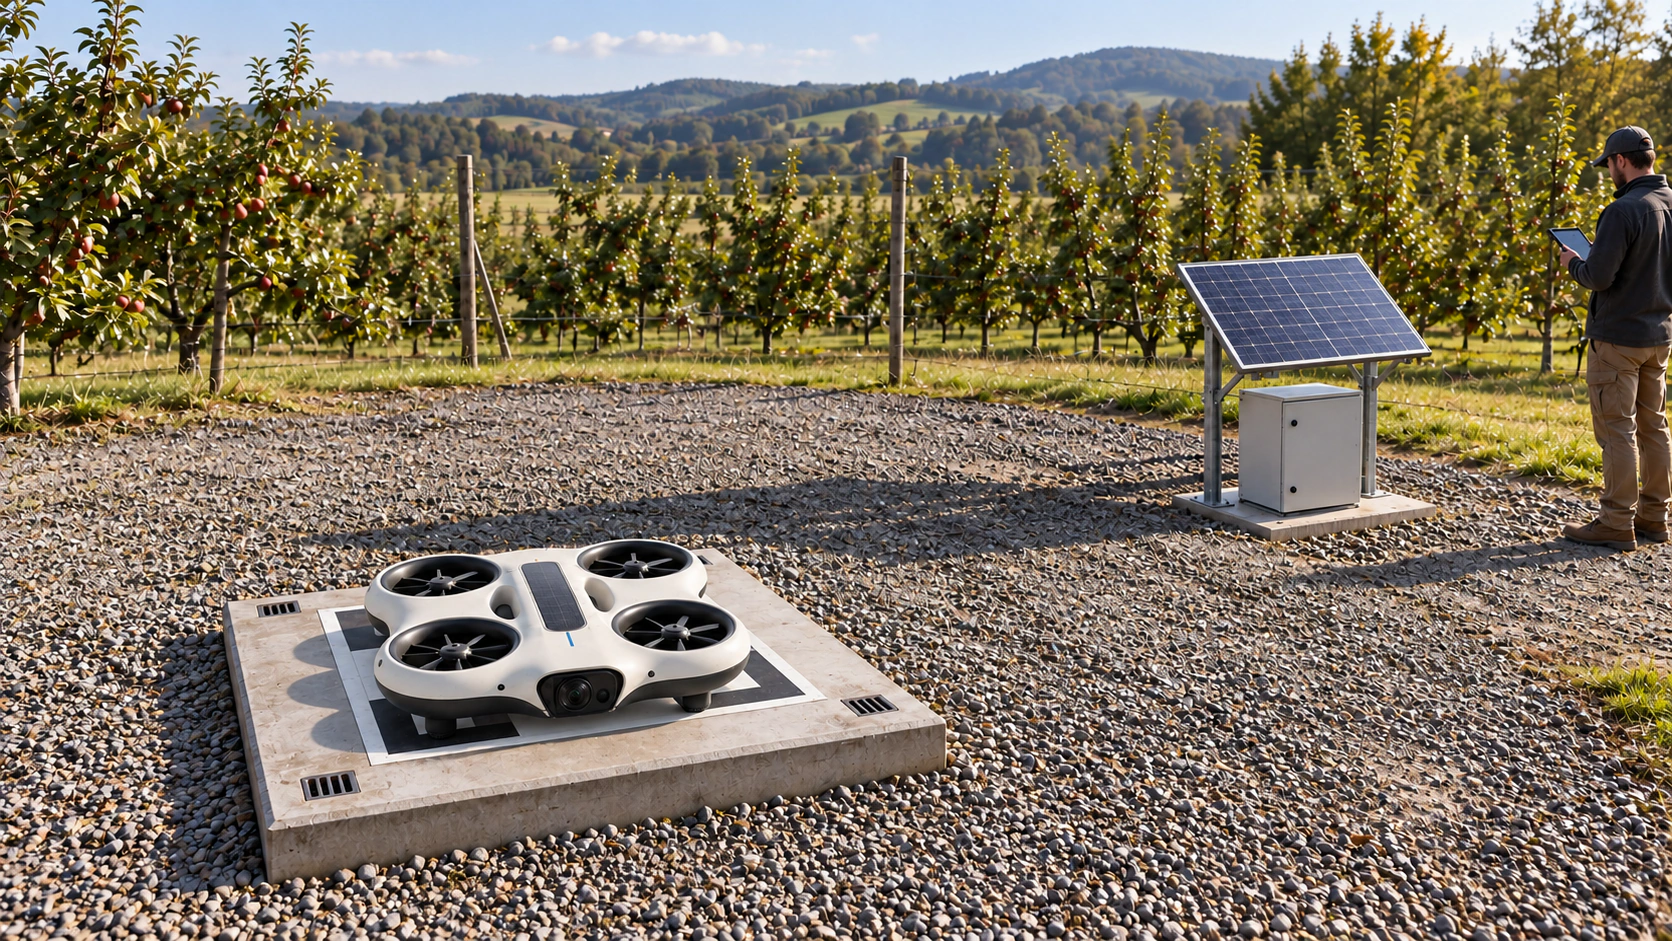
The talk, Network Degradation and Mission Continuity, examines a practical challenge for connected robotics: what should happen when machines and operators no longer share a reliable view of a mission?
- Date: Friday, 13 November 2026
- Time: 13:00–14:00 UK / 16:00–17:00 Türkiye
- Format: online; joining information is published by CRANE
- Speaker: Bayram Yüksel Eker, Founder and Technical Lead, Neura Parse Ltd
- SIG main contacts: Dr. John A Clark, Professor of Computer and Information Security and SIG lead, University of Sheffield; Dr. Jims Marchang, Senior Lecturer in Cybersecurity, Sheffield Hallam University
Reconnecting is not the same as knowing what happened
A lost connection is not simply an interruption in data transfer. An instruction may have been executed without its acknowledgement arriving. A robot may continue operating locally while the coordinating system has an incomplete record of its actions.
Reconnecting the network does not, by itself, establish what happened or whether the next command is appropriate.
Supervised continuity, uncertain states and evidence-based recovery
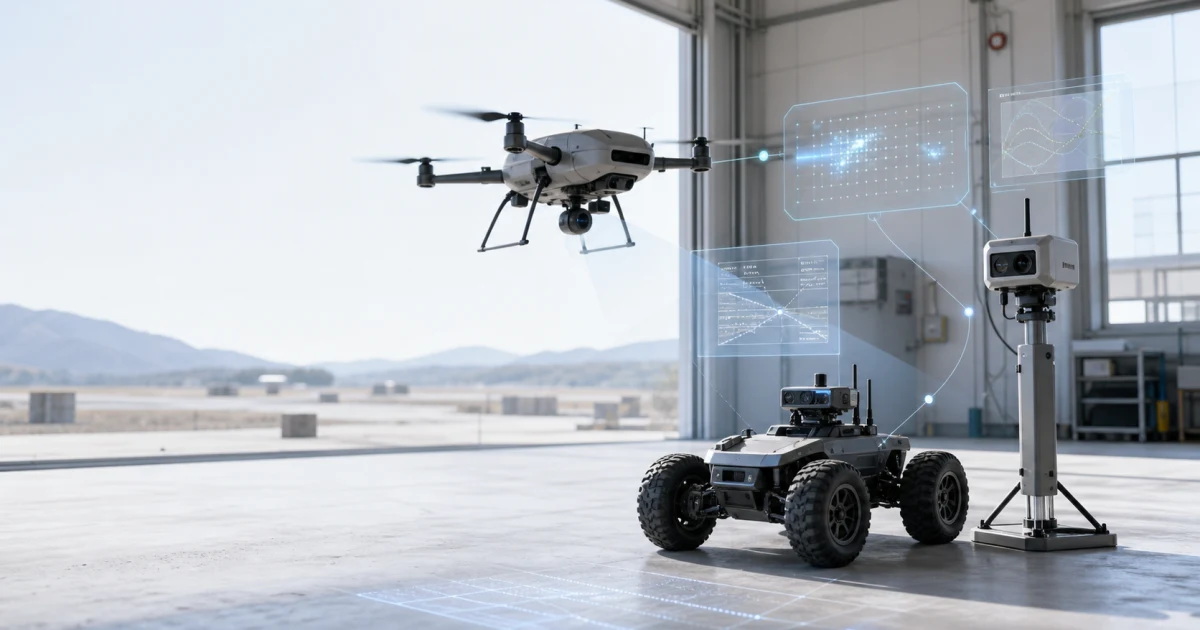
Drawing on Neura Parse’s NODERIQ research direction, the presentation will explore supervised mission continuity, uncertain task states, bounded local operations and evidence-based recovery through an illustrative inspection scenario.
The discussion will distinguish current software and simulation work from prospective controlled network and physical-robot evaluations. It is a research discussion, not a report of completed physical field trials.
BA · Bulletin annexDefinitions, recurring questions, source notes, and publication tags.Inspect
SNSource notes
4 recordsTags